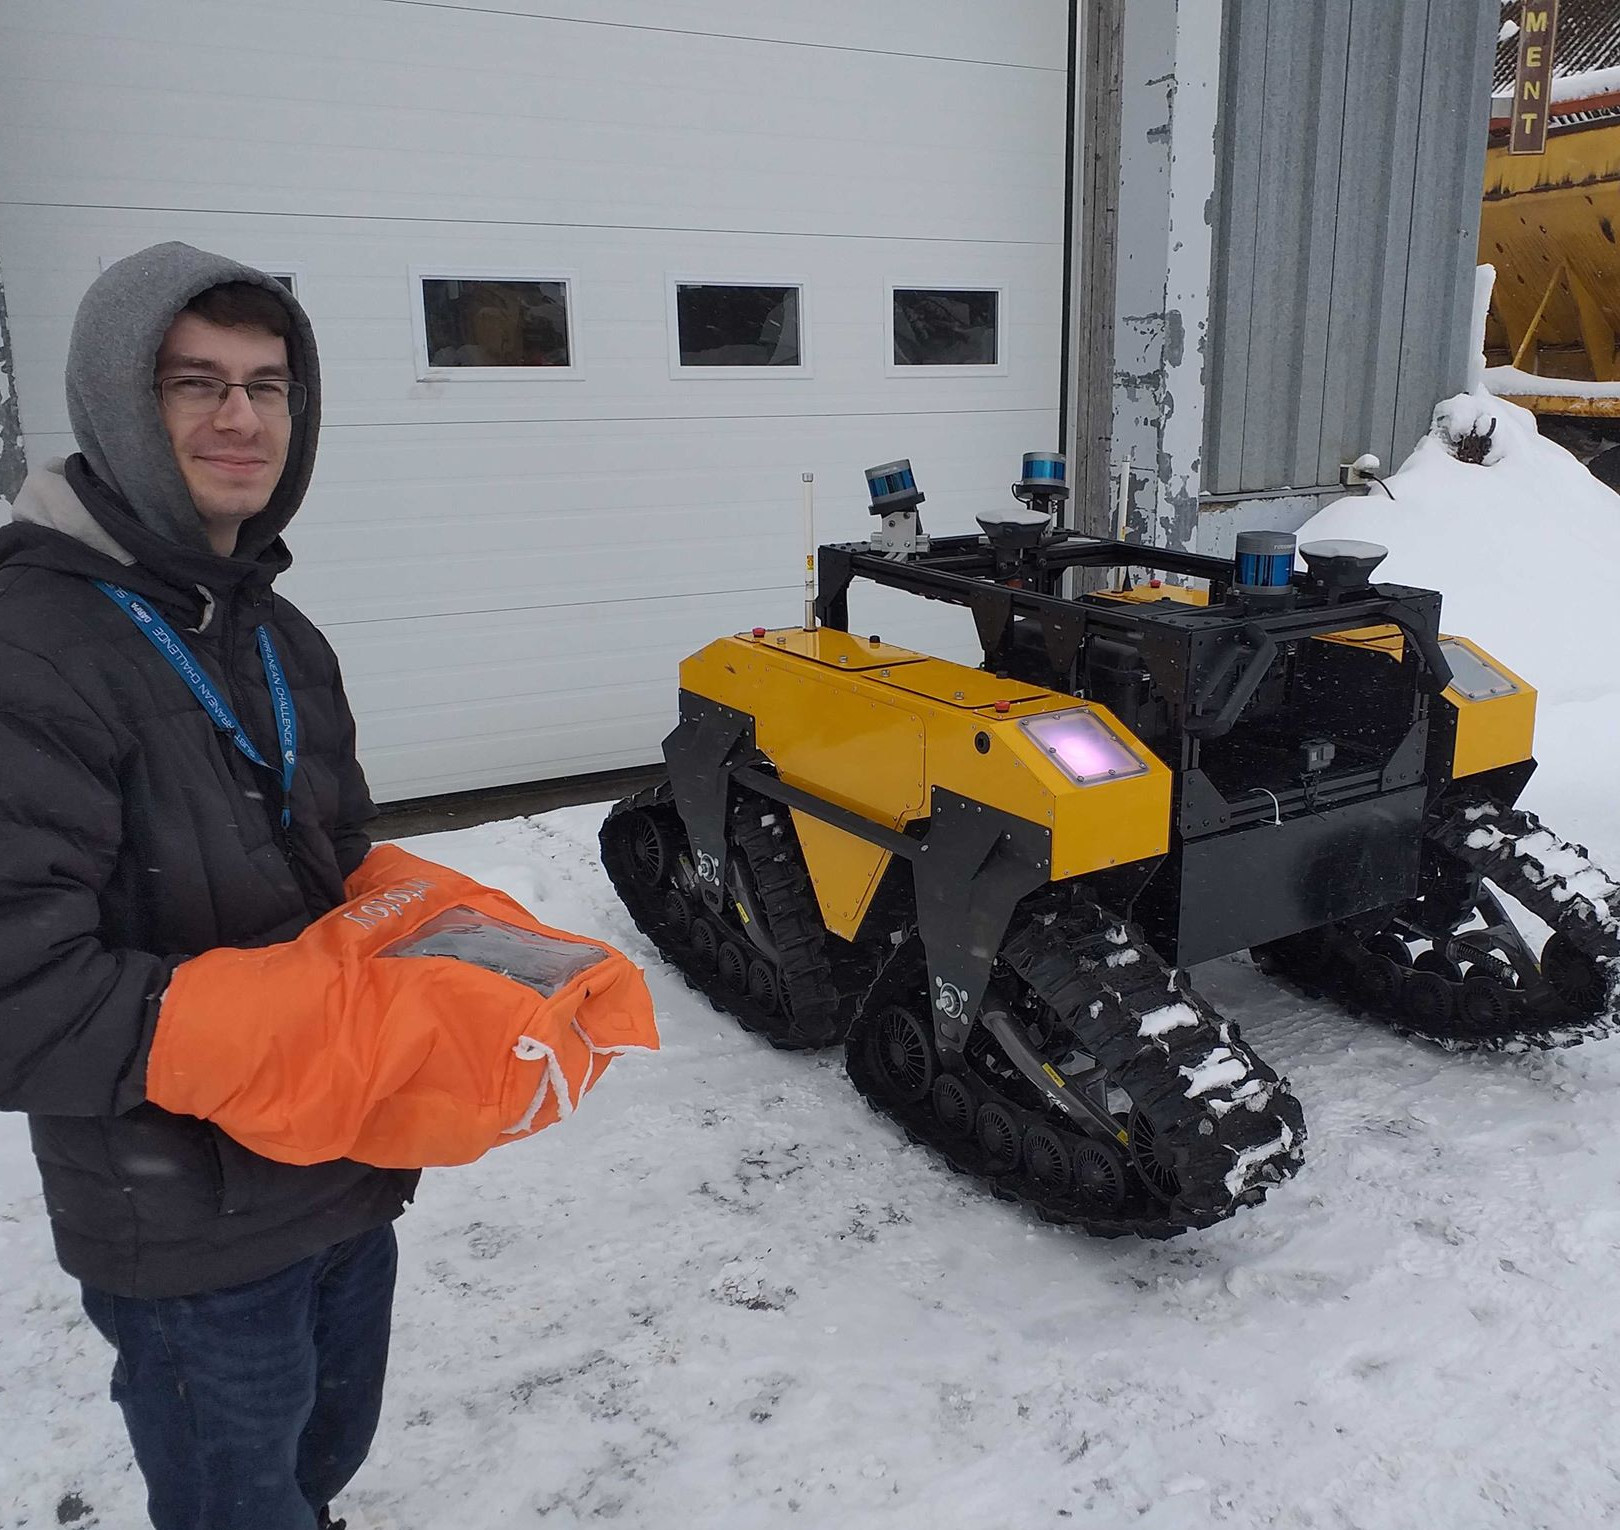
Simon-Pierre Deschênes est un étudiant au doctorat au sein du Norlab sous la supervision du Pr. François Pomerleau. Ayant effectué un stage au sein du laboratoire à l’été 2018 dans le cadre de son baccalauréat, Simon-Pierre a été captivé par la cartographie 3D et a décidé de poursuivre ses études supérieures dans ce domaine. Son projet de recherche s’insère dans le projet SNOW et porte sur la cartographie et la localisation 3D en conditions hivernales diffiles à l’aide de l’algorithme ICP. La participation des différents membres du projet leur a permis d’atteindre et même de surpasser les objectifs du premier jalon. Voici une démonstration du système mis en place dans le cadre de ce projet :
Enfin, Simon-Pierre a participé à plusieurs autres projets depuis son arrivée au laboratoire, dont le vidéo de Noël 2019 du Norlab dont il a dirigé la réalisation :
Education
-
Maîtrise en informatique à l’Université Laval (passage accéléré au doctorat), 2020
-
Baccalauréat en génie logiciel à l’Université Laval, 2019
Publications
Journal Articles
- Deschênes, S.-P., Vannini, V., Giguère, P., & Pomerleau, F. (2026). Stretch-ICP: A Continuous-Trajectory Registration and Deskewing Algorithm in Scenarios of Aggressive Motions. Sensors, 26(8). https://doi.org/10.3390/s26082567
PDF Publisher Bibtex source - Ebadi, K., Bernreiter, L., Biggie, H., Catt, G., Chang, Y., Chatterjee, A., Denniston, C. E., Deschênes, S.-P., Harlow, K., Khattak, S., Nogueira, L., Palieri, M., Petráček, P., Petrlík, M., Reinke, A., Krátký, V., Zhao, S., Agha-Mohammadi, A.-A., Alexis, K., … Carlone, L. (2023). Present and Future of SLAM in Extreme Environments: The DARPA SubT Challenge. IEEE Transactions on Robotics (T-RO). https://doi.org/10.1109/TRO.2023.3323938
Publisher Bibtex source - Baril, D., Deschênes, S.-P., Gamache, O., Vaidis, M., LaRocque, D., Laconte, J., Kubelka, V., Giguère, P., & Pomerleau, F. (2022). Kilometer-scale autonomous navigation in subarctic forests: challenges and lessons learned. Field Robotics, 2(1), 1628–1660. https://doi.org/10.55417/fr.2022050
PDF Publisher Bibtex source
Conference Articles
- Deschênes, S.-P., Baril, D., Boxan, M., Laconte, J., Giguère, P., & Pomerleau, F. (2024). Saturation-Aware Angular Velocity Estimation: Extending the Robustness of SLAM to Aggressive Motions. 2024 IEEE International Conference on Robotics and Automation (ICRA), 10711–10718. https://doi.org/10.1109/ICRA57147.2024.10610361
PDF Publisher Bibtex source - Baril, D., Deschênes, S.-P., Coupal, L., Goffin, C., Lépine, J., Giguère, P., & Pomerleau, F. (2024). DRIVE: Data-driven Robot Input Vector Exploration. Proceedings of the IEEE International Conference on Robotics and Automation (ICRA). https://doi.org/10.1109/ICRA57147.2024.10611172
Publisher Bibtex source - Deschênes, S.-P., Baril, D., Kubelka, V., Giguère, P., & Pomerleau, F. (2021). Lidar Scan Registration Robust to Extreme Motions. 2021 18th Conference on Robots and Vision (CRV). https://doi.org/10.1109/CRV52889.2021.00014
PDF Publisher Bibtex source - Baril, D., Grondin, V., Deschenes, S., Laconte, J., Vaidis, M., Kubelka, V., Gallant, A., Giguere, P., & Pomerleau, F. (2020). Evaluation of Skid-Steering Kinematic Models for Subarctic Environments. 2020 17th Conference on Computer and Robot Vision (CRV), 198–205. https://doi.org/10.1109/CRV50864.2020.00034 Best Robotic Vision Paper Award!
PDF Publisher Bibtex source - Laconte, J., Deschênes, S.-P., Labussière, M., & Pomerleau, F. (2019). Lidar Measurement Bias Estimation via Return Waveform Modelling in a Context of 3D Mapping. Proceedings of the IEEE International Conference on Robotics and Automation (ICRA).
PDF Bibtex source
Miscellaneous
- Jeanson, G., Duclos, D.-A., Larrivée-Hardy, W., Cochet, N., Boxan, M., Deschênes, A., Pomerleau, F., & Giguère, P. (2026). Leveraging Image Generators to Address Training Data Scarcity: The Gen4Regen Dataset for Forest Regeneration Mapping. Colloque REPARTI, Université Laval.
Bibtex source - Deschênes, S.-P., Baril, D., Kubelka, V., Giguère, P., & Pomerleau, F. (2023). Lidar Scan Registration Robust to Extreme Motions. Colloque REPARTI, Université Laval.
Bibtex source